
-
 Forklift handling mobile robot
 Reach mobile robots
 SLIM
 Jacking robot
 Cooperation robot
 Roller mobile robot
 Towing mobile robot
 Platform handling robot
 Heavy-load robot
 Outdoor loading mobile robot
 Pick robot
 Parking robot
 Agricultural robot
 Driverless Road Roller robot
 Driverless Sanitation vehicle


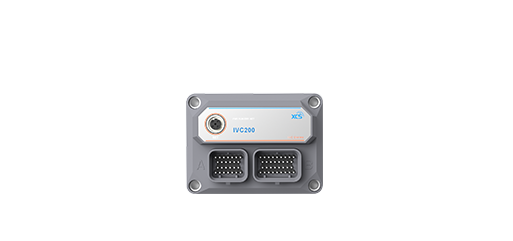


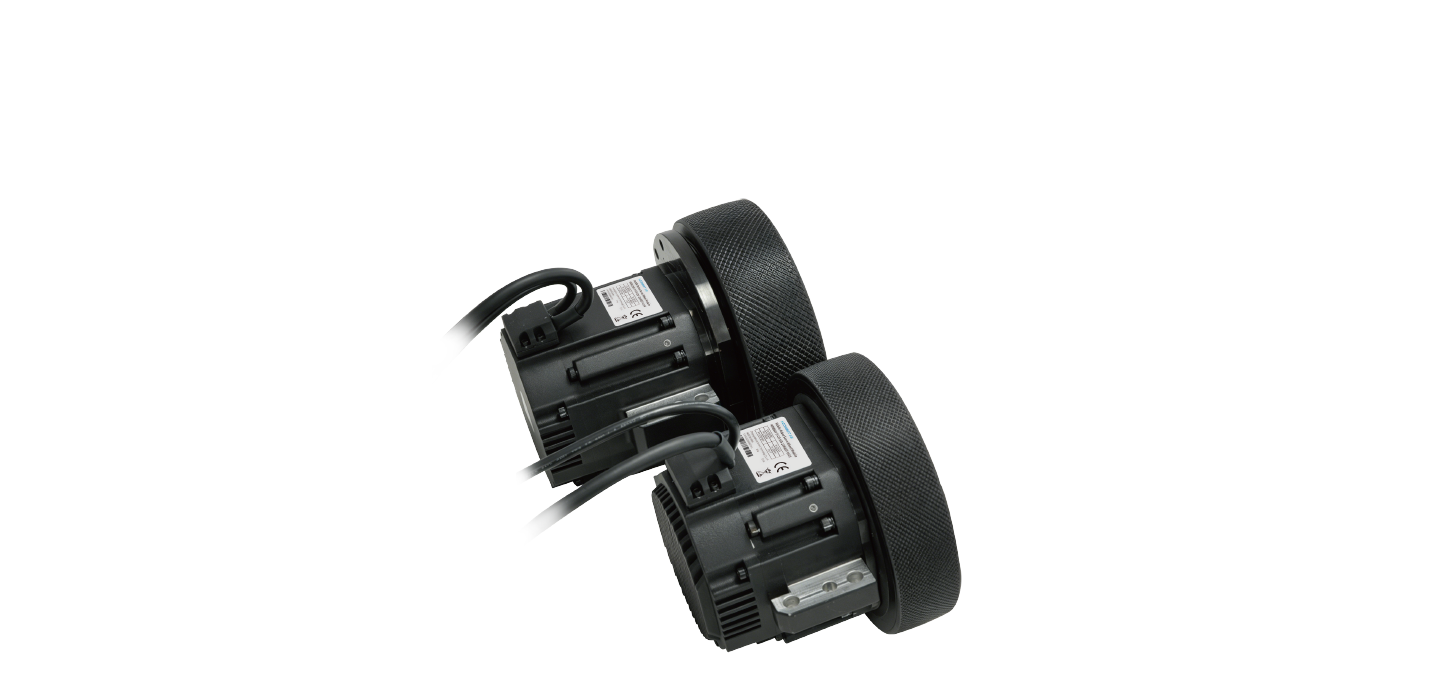
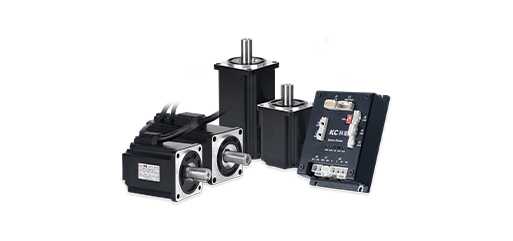
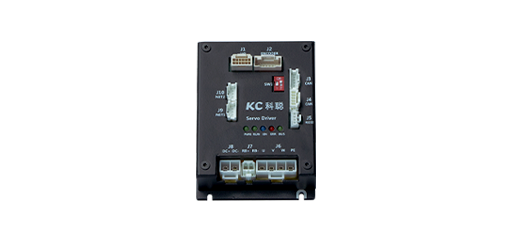





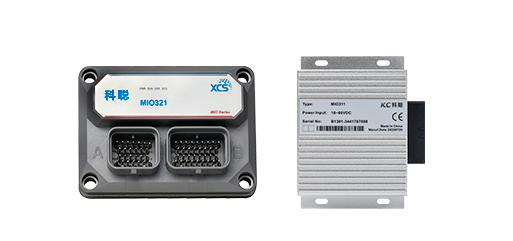
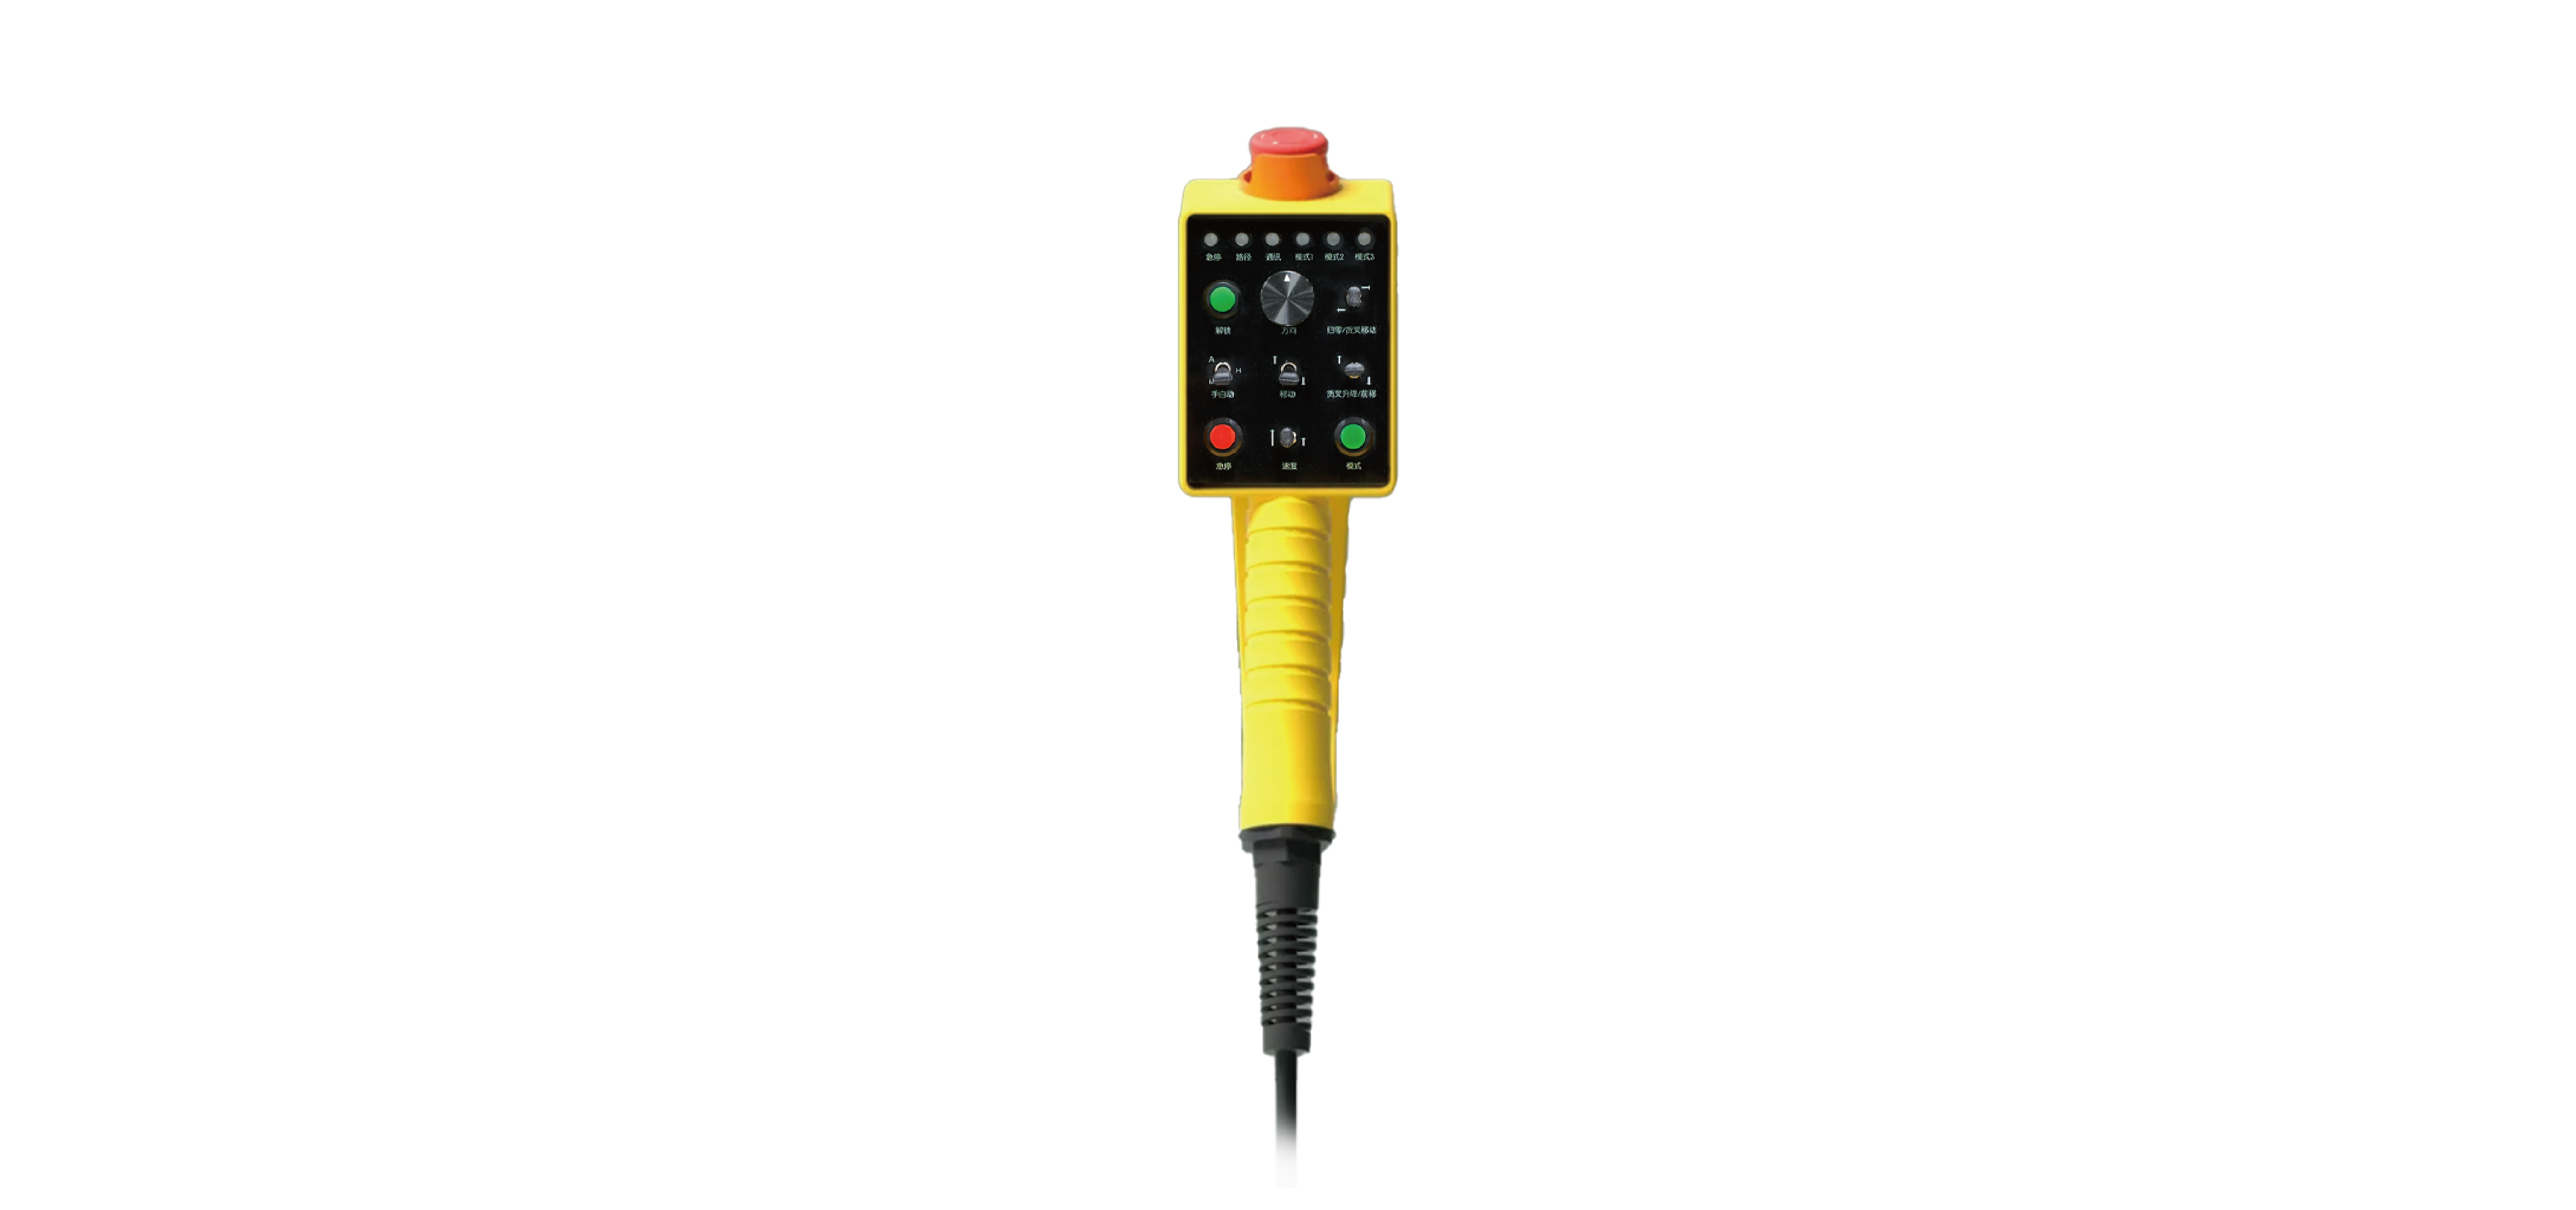


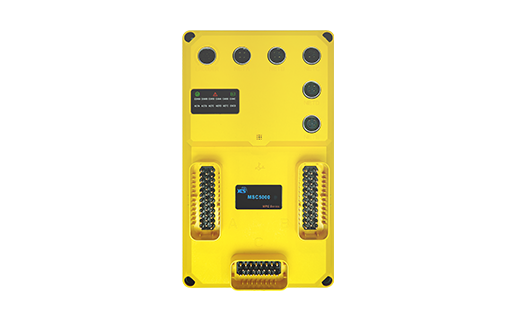




Model | MSC5000 | |
Description | Name | Safety Mobile Robot Controller |
Dimensions | Dimensions W x H x D (mm) | 215×125×56 (excluding connector contacts) |
Safety Certification | Safety Integrity Level | IEC 61508 SIL3,SC3 IEC 62061 SIL3 |
Performance Level | ISO 13849 Cat 3,PLe | |
Safety Architecture | Safety Architecture | 1oo2 |
Product Certification | CE | EMC(EN IEC 61326-1) LVD(IEC 61010-1、IEC 61010-2) |
Protection Rating | IP65 | |
Operating Environment | Temperature | -30℃~+70℃ |
Humidity | 10%–95% RH, No Condensation | |
Altitude | Below 2000 m | |
EMC | Industrial Level 3 | |
Network Interface | Wired Industrial Ethernet | 5 |
Safety Interfaces | SO | 4(24V/1.5A) |
DIO | 36 | |
Encoder Interface | 2 | |
Power Supply | 24VDC | |
General Interfaces | DI/DO/DIO | 8/4/4 |
Encoder Interface | 2 | |
CAN (Channels) | 3 | |
RS485 (Channels) | 2 | |
Multiplex Communication Port (Channels) | 1 (Configurable as CAN/RS485/RS232) | |
Power Supply | (18~60)VDC | |
Navigation Performance | Navigation Method | 2D/3D LiDAR Navigation, QR-Code Navigation, Magnetic Navigation, GNSS Navigation |
Navigation Accuracy | ±5mm ±2mm(Reflector) | |
Chassis Motion Models | 2-Wheel Differential, 4-Wheel Differential, Single Steer Wheel, Dual Steer Wheels, Four Steer Wheels, Differential Drive Module, Mecanum Wheels, Ackermann Chassis, etc. | |
Chassis Map Area | ≤1,000,000 m² | |


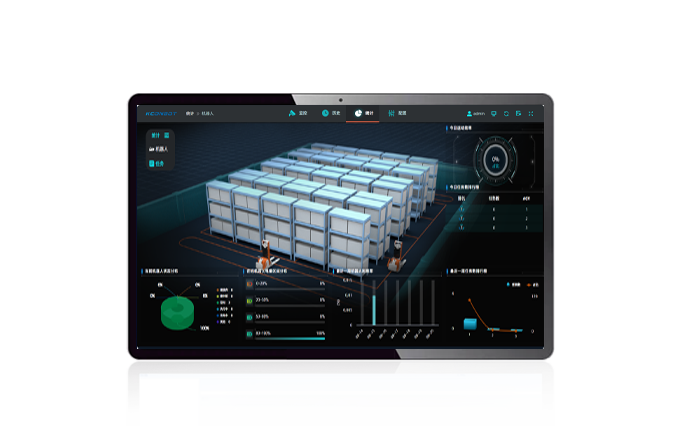
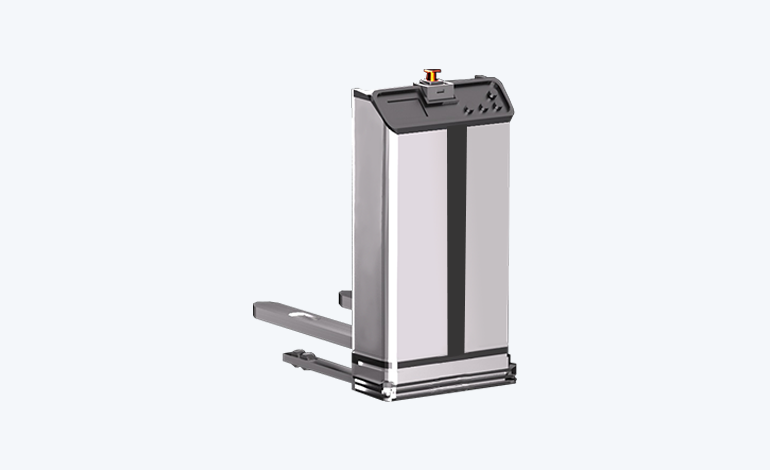
The overall solution of fork-type handling mobile robot is mainly divided into nine modules according to the whole vehicle function of the mobile robot, such as control system, navigation and sensing, chassis drive, actuator, safety detection, interaction module, communication module, power supply unit, and optional functions.
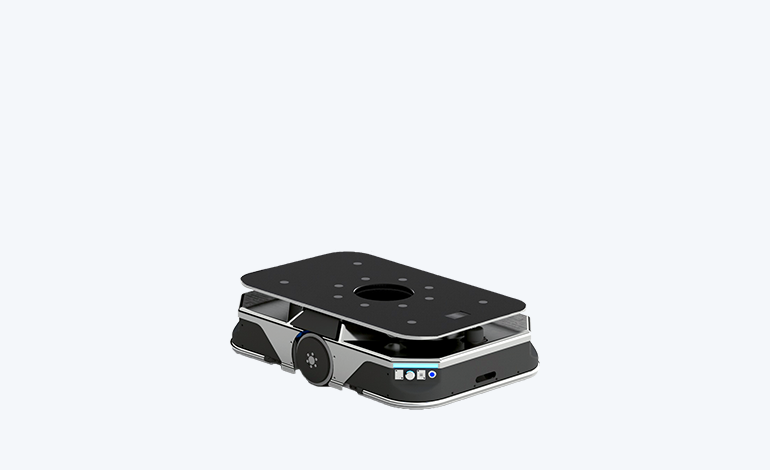
The overall solution of jacking and transporting type, according to the whole vehicle function of mobile robot, is mainly divided into the control system, navigation, and sensing, chassis drive, actuator, safety detection, interaction module, communication module, power supply unit, optional additional functions, such as the composition of the nine major unit modules.
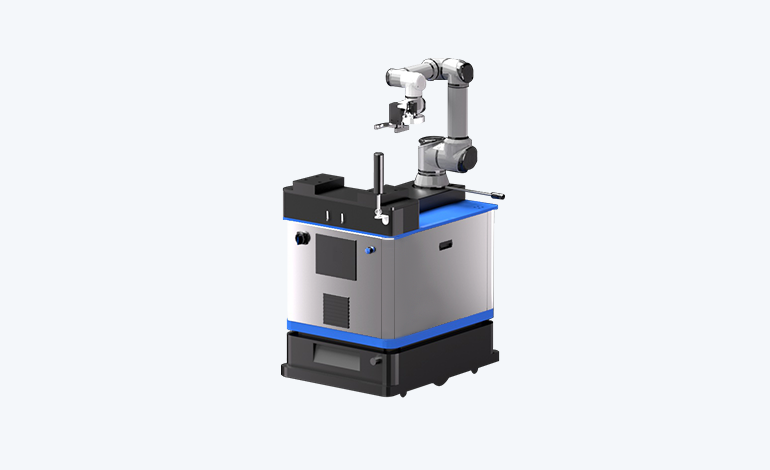
The cooperation mobile robot's overall solution, according to the mobile robot vehicle function, is mainly divided into the control system, navigation sensing, chassis drive, actuator, safety detection, interaction module, communication module, power supply unit, and optional functions, such as nine unit module composition.
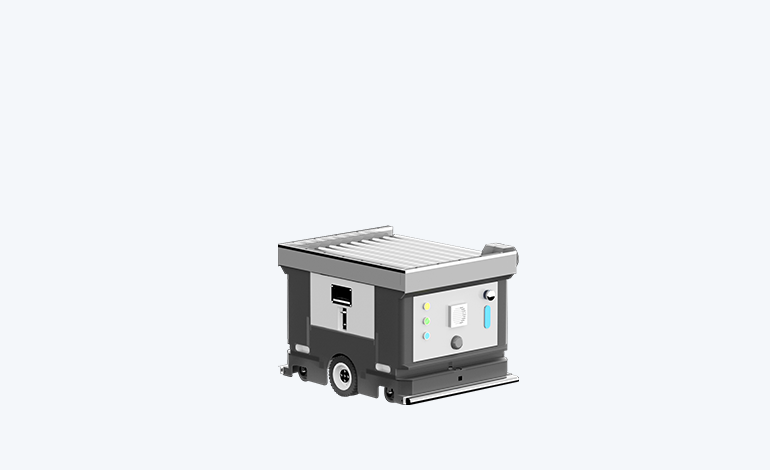
The overall solution of the roller mobile robot is mainly divided into nine unit modules, such as control system, navigation and sensing, chassis drive, actuator, safety detection, interaction module, communication module, power supply unit, and add functions, etc., according to the function of the whole vehicle of the mobile robot.

According to the whole vehicle function of the mobile robot, the overall solution of the bin-type mobile robot is mainly divided into control system, navigation and sensing, chassis drive, actuator, safety detection, interaction module, communication module, power supply unit, add functions and other nine unit modules.

The overall solution of a traction mobile robot is mainly divided into control system, navigation and sensing, chassis drive, safety detection, interaction module, communication module, power supply unit, add functions, and other units and modules according to the function of the whole vehicle of the mobile robot.

The overall solution for heavy-duty mobile robots is mainly divided into the control system, navigation and sensing, chassis drive, safety detection, interaction module, communication module, power supply unit, add functions, and other modules according to the function of the whole vehicle of the mobile robot.
