
-
 Forklift handling mobile robot
 Reach mobile robots
 SLIM
 Jacking robot
 Cooperation robot
 Roller mobile robot
 Towing mobile robot
 Platform handling robot
 Heavy-load robot
 Outdoor loading mobile robot
 Pick robot
 Parking robot
 Agricultural robot
 Driverless Road Roller robot
 Driverless Sanitation vehicle









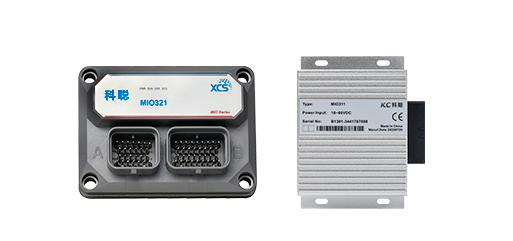
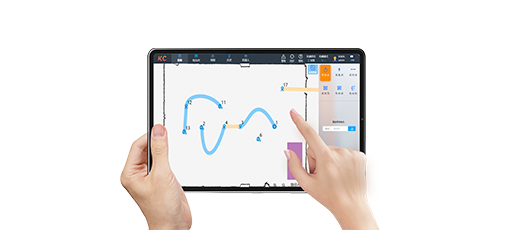
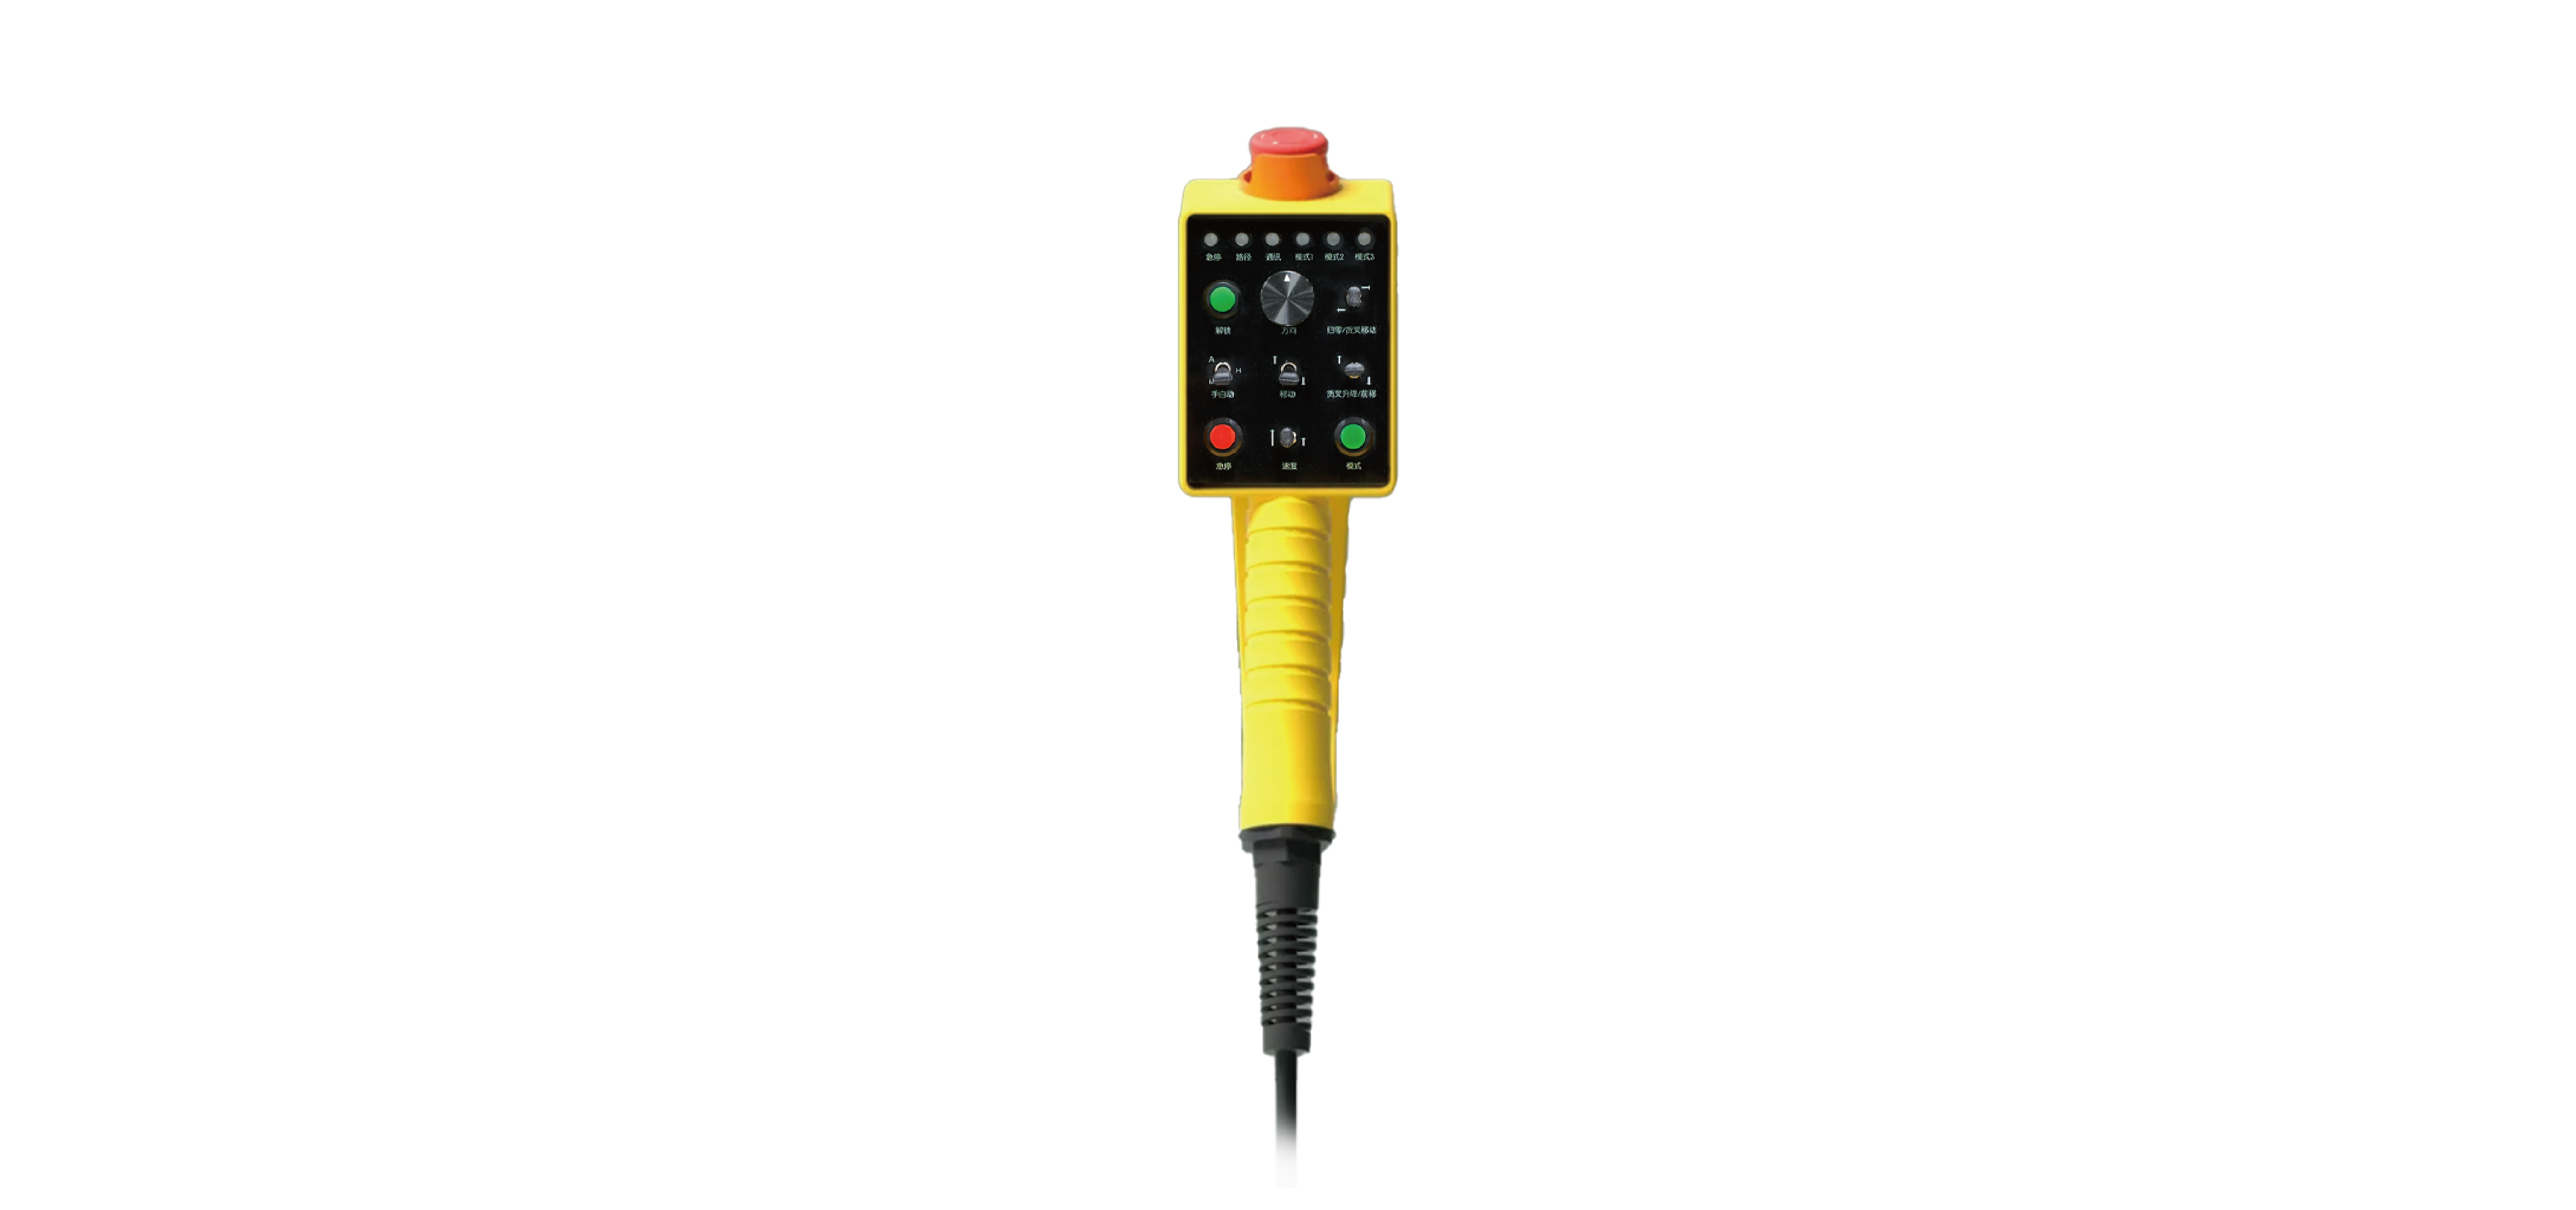


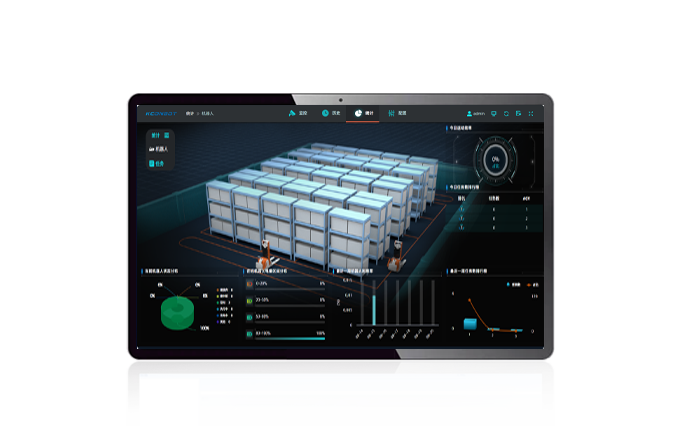


KCONBOT Robot Application Software is independently designed and developed by Zhejiang Kecong for robot application deployment. It includes robot model management, map management, and scheduling configuration management. An intuitive HMI enables implementation engineers to rapidly build application maps and deploy functions across different scenarios. Flexible path-building tools support quick route creation, while intelligent encapsulation of complex deployment processes simplifies engineering work and enables fast, efficient commissioning.
On-Site Map Scanning: For a new site, the first map can be created simply by manually driving the robot while the system automatically records the environment. The same map can be reused by different robots in the same site.
Robot Calibration: Mechanical tolerances and software-parameter differences can arise during manufacturing and installation. Automatic calibration tools are used to compensate for these differences and improve consistency.
Task Point & Path Creation: Add task points to an existing map and connect them to complete route setup. Arc, straight-line, polyline, and other path types are supported to meet different requirements.
Task Step Configuration: After the preceding setup, task logic can be configured in the task configuration tool so that a single robot executes simple tasks step by step.


