
-
 Forklift handling mobile robot
 Reach mobile robots
 SLIM
 Jacking robot
 Cooperation robot
 Roller mobile robot
 Towing mobile robot
 Platform handling robot
 Heavy-load robot
 Outdoor loading mobile robot
 Pick robot
 Parking robot
 Agricultural robot
 Driverless Road Roller robot
 Driverless Sanitation vehicle









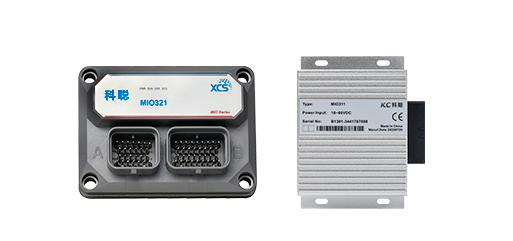
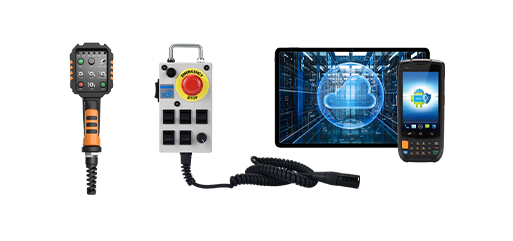
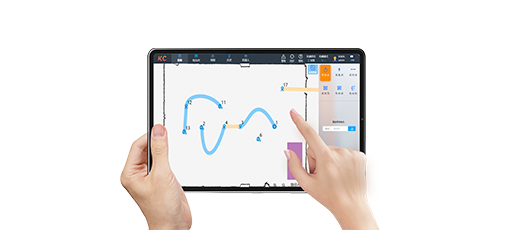
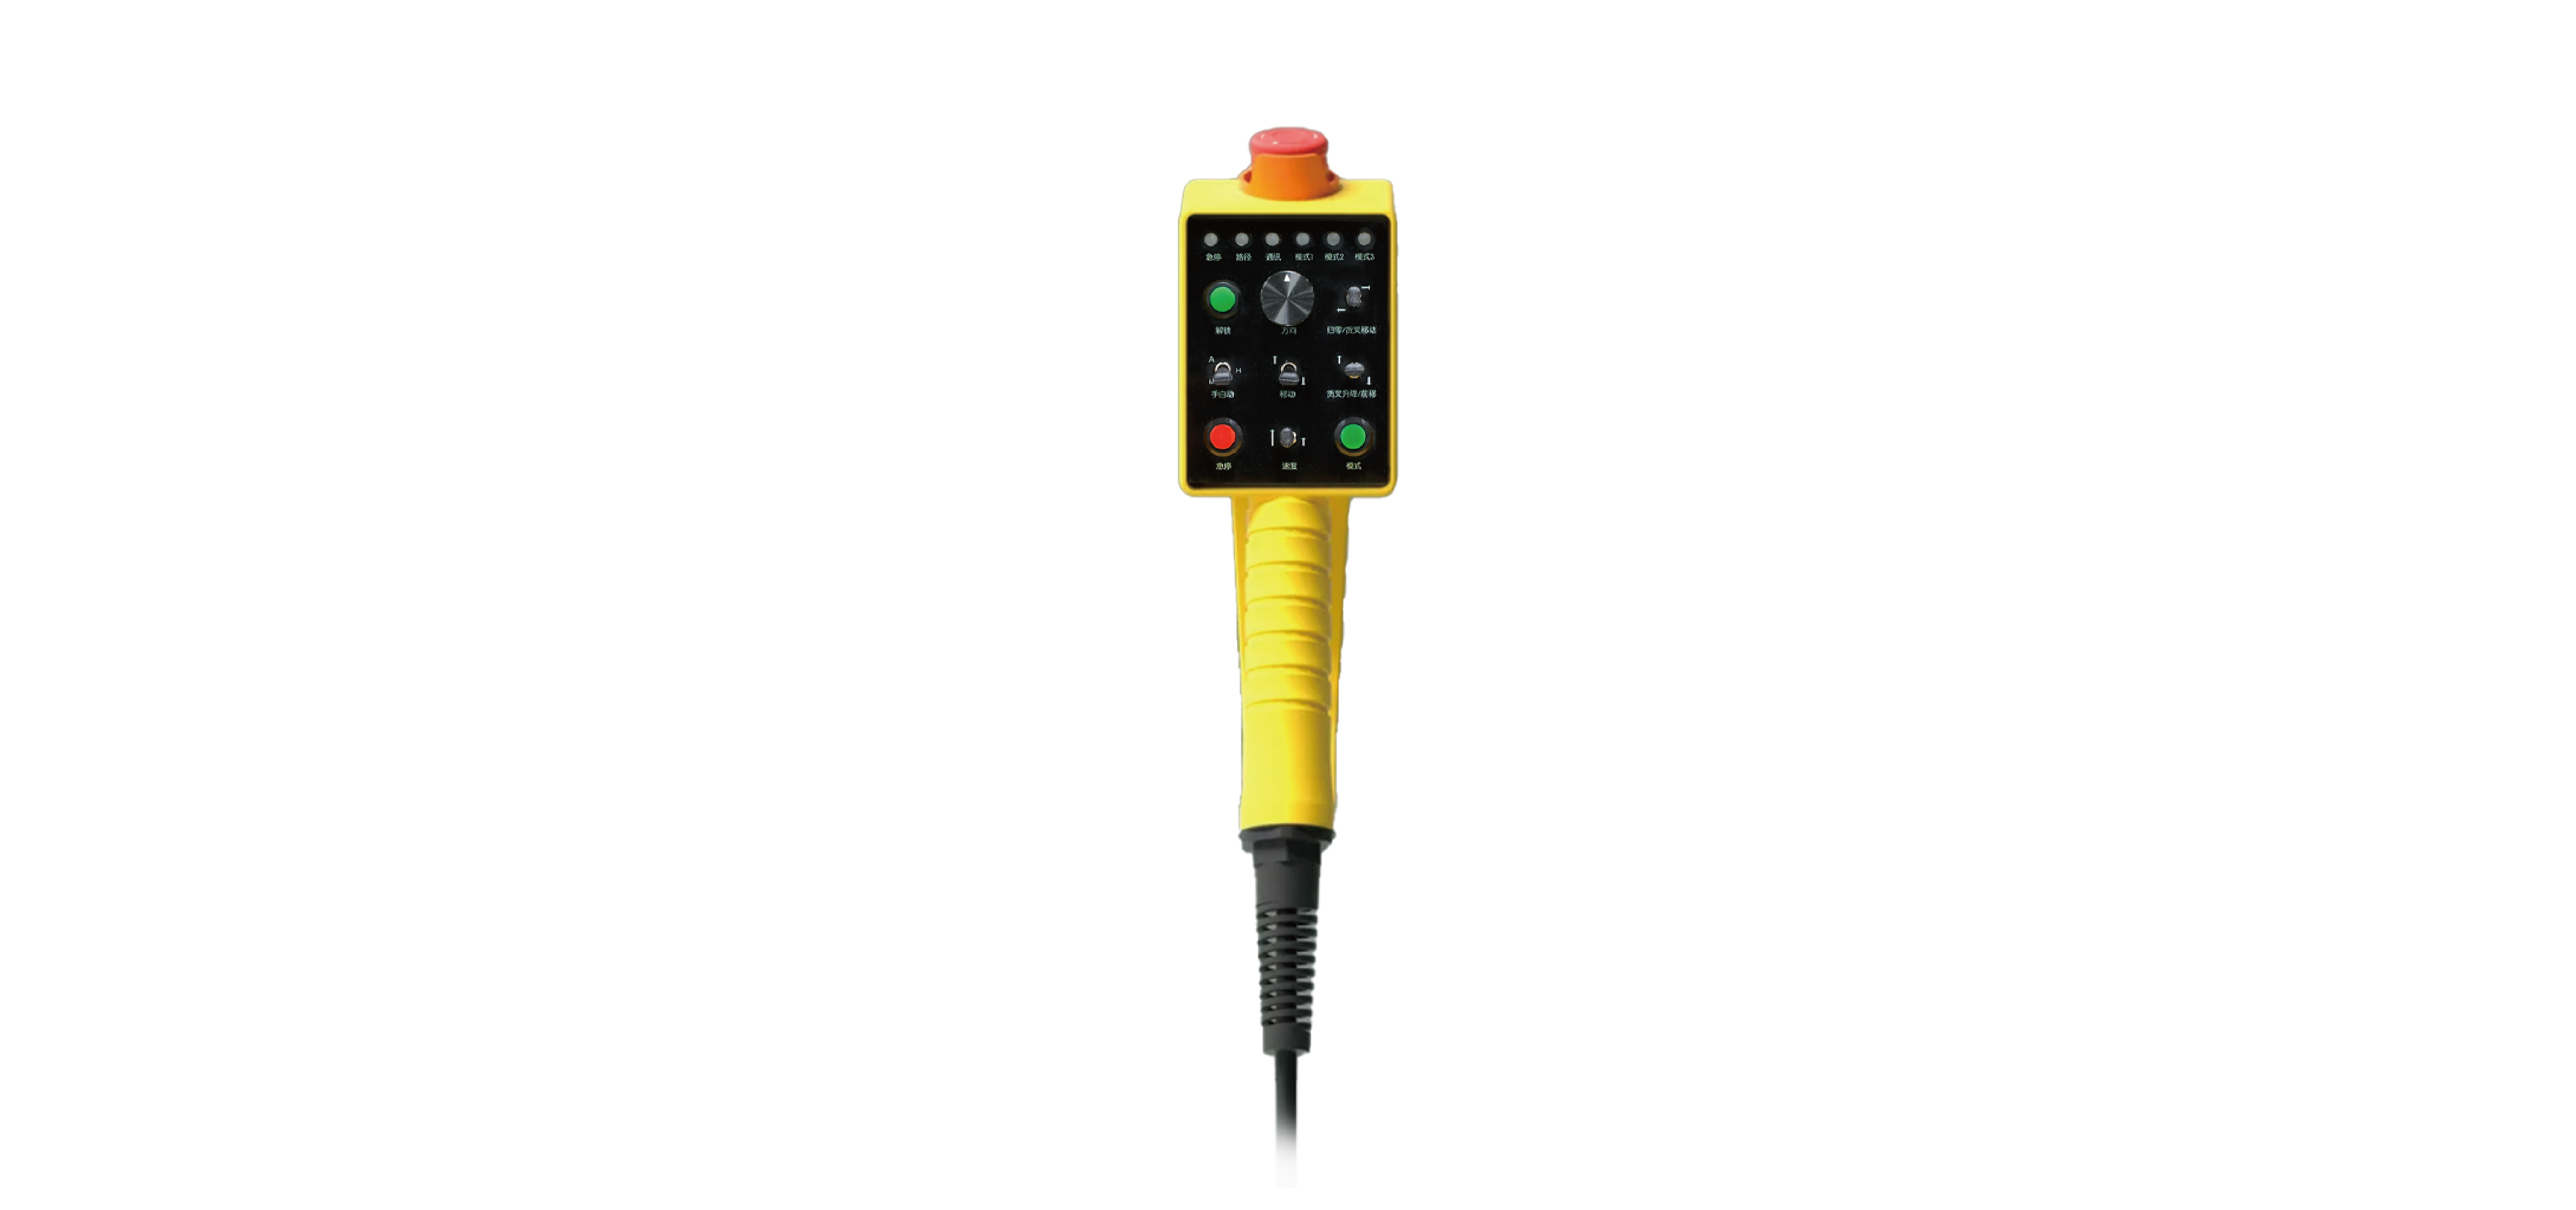


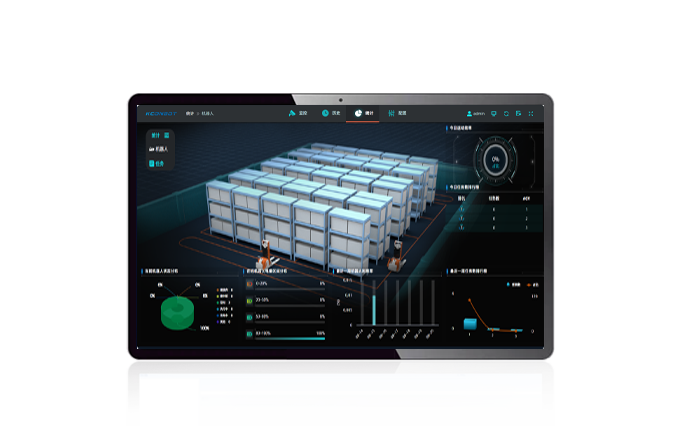


KCONBOT Robot Fleet Monitoring & Scheduling Software is a proprietary multi-agent intelligent management platform. It includes an AGV fleet management system and a monitoring/display interaction system, providing task assignment, traffic scheduling, operation and maintenance, monitoring visualization, task-flow configuration, Python programming, and more for multiple robot types. Using multiple AI-based scheduling algorithms, it optimizes robot task allocation, multi-robot path planning, and traffic management, enabling coordinated work among robots, between robots and automation equipment, across robot fleets, and between robots and people. It provides an efficient foundation for robot applications, smart factories, intelligent manufacturing, and smart cities.
Multi-Dimensional Data Analysis: A well-structured layout makes analytics dashboards more flexible, improves space utilization, and balances chart proportions for clearer and more intuitive data visualization.
Graphical Task-Chain Function: Based on the KCONBOT digital technology engine, task workflows can be created by drag-and-drop graphical modules with no coding required.
Integrated Python Development Tool: Embedded Python development integrates seamlessly with graphical design. Edited scheduling tasks can be packaged as reusable modules for later use.
Enhanced Deployment Security: High-reliability secure communication technologies—including asymmetric encryption, key-based identity authentication, encrypted channels, and security certificates—strengthen data protection.

With advanced traffic control for multiple robots operating in parallel, it ensures smooth operations and zero path conflicts.
By prioritizing workflows and task urgency, the platform achieves true multi-task parallel scheduling for maximum efficiency.
Even before execution begins, the system predicts potential conflict points and coordinates actions in advance — minimizing delays and preventing disruptions.

Whether it’s cargo blockage or task delays, the system automatically triggers alerts and delivers synchronized notifications through both onboard terminals and the central monitoring platform.
With built-in video recording and playback, users can easily trace and review up to one month of operation footage — ensuring full visibility, accountability, and peace of mind.

It supports large-scale testing with 1,000+ AGVs running simultaneously, providing unmatched scalability.
By combining simulation with real-vehicle operations, the platform validates both the feasibility and robustness of your automation solutions — helping you deploy with confidence.

This ensures flexible, efficient, and uninterrupted production workflows, enabling smarter automation and higher productivity on the shop floor.

By turning past operational data into actionable insights, the system empowers businesses to optimize dispatching strategies and resource allocation, driving smarter decisions and greater efficiency.

Achieve faster time-to-value with hassle-free deployment and seamless business verification.
